Projects
Research exploration, engineering competitions, and technical projects.
Blueberry Maturity Detection and RGB-D Data Management
This project develops visual perception and data infrastructure for a blueberry harvesting robot. It combines a YOLOv8-based maturity detector with an RGB-D acquisition and dataset-management system.
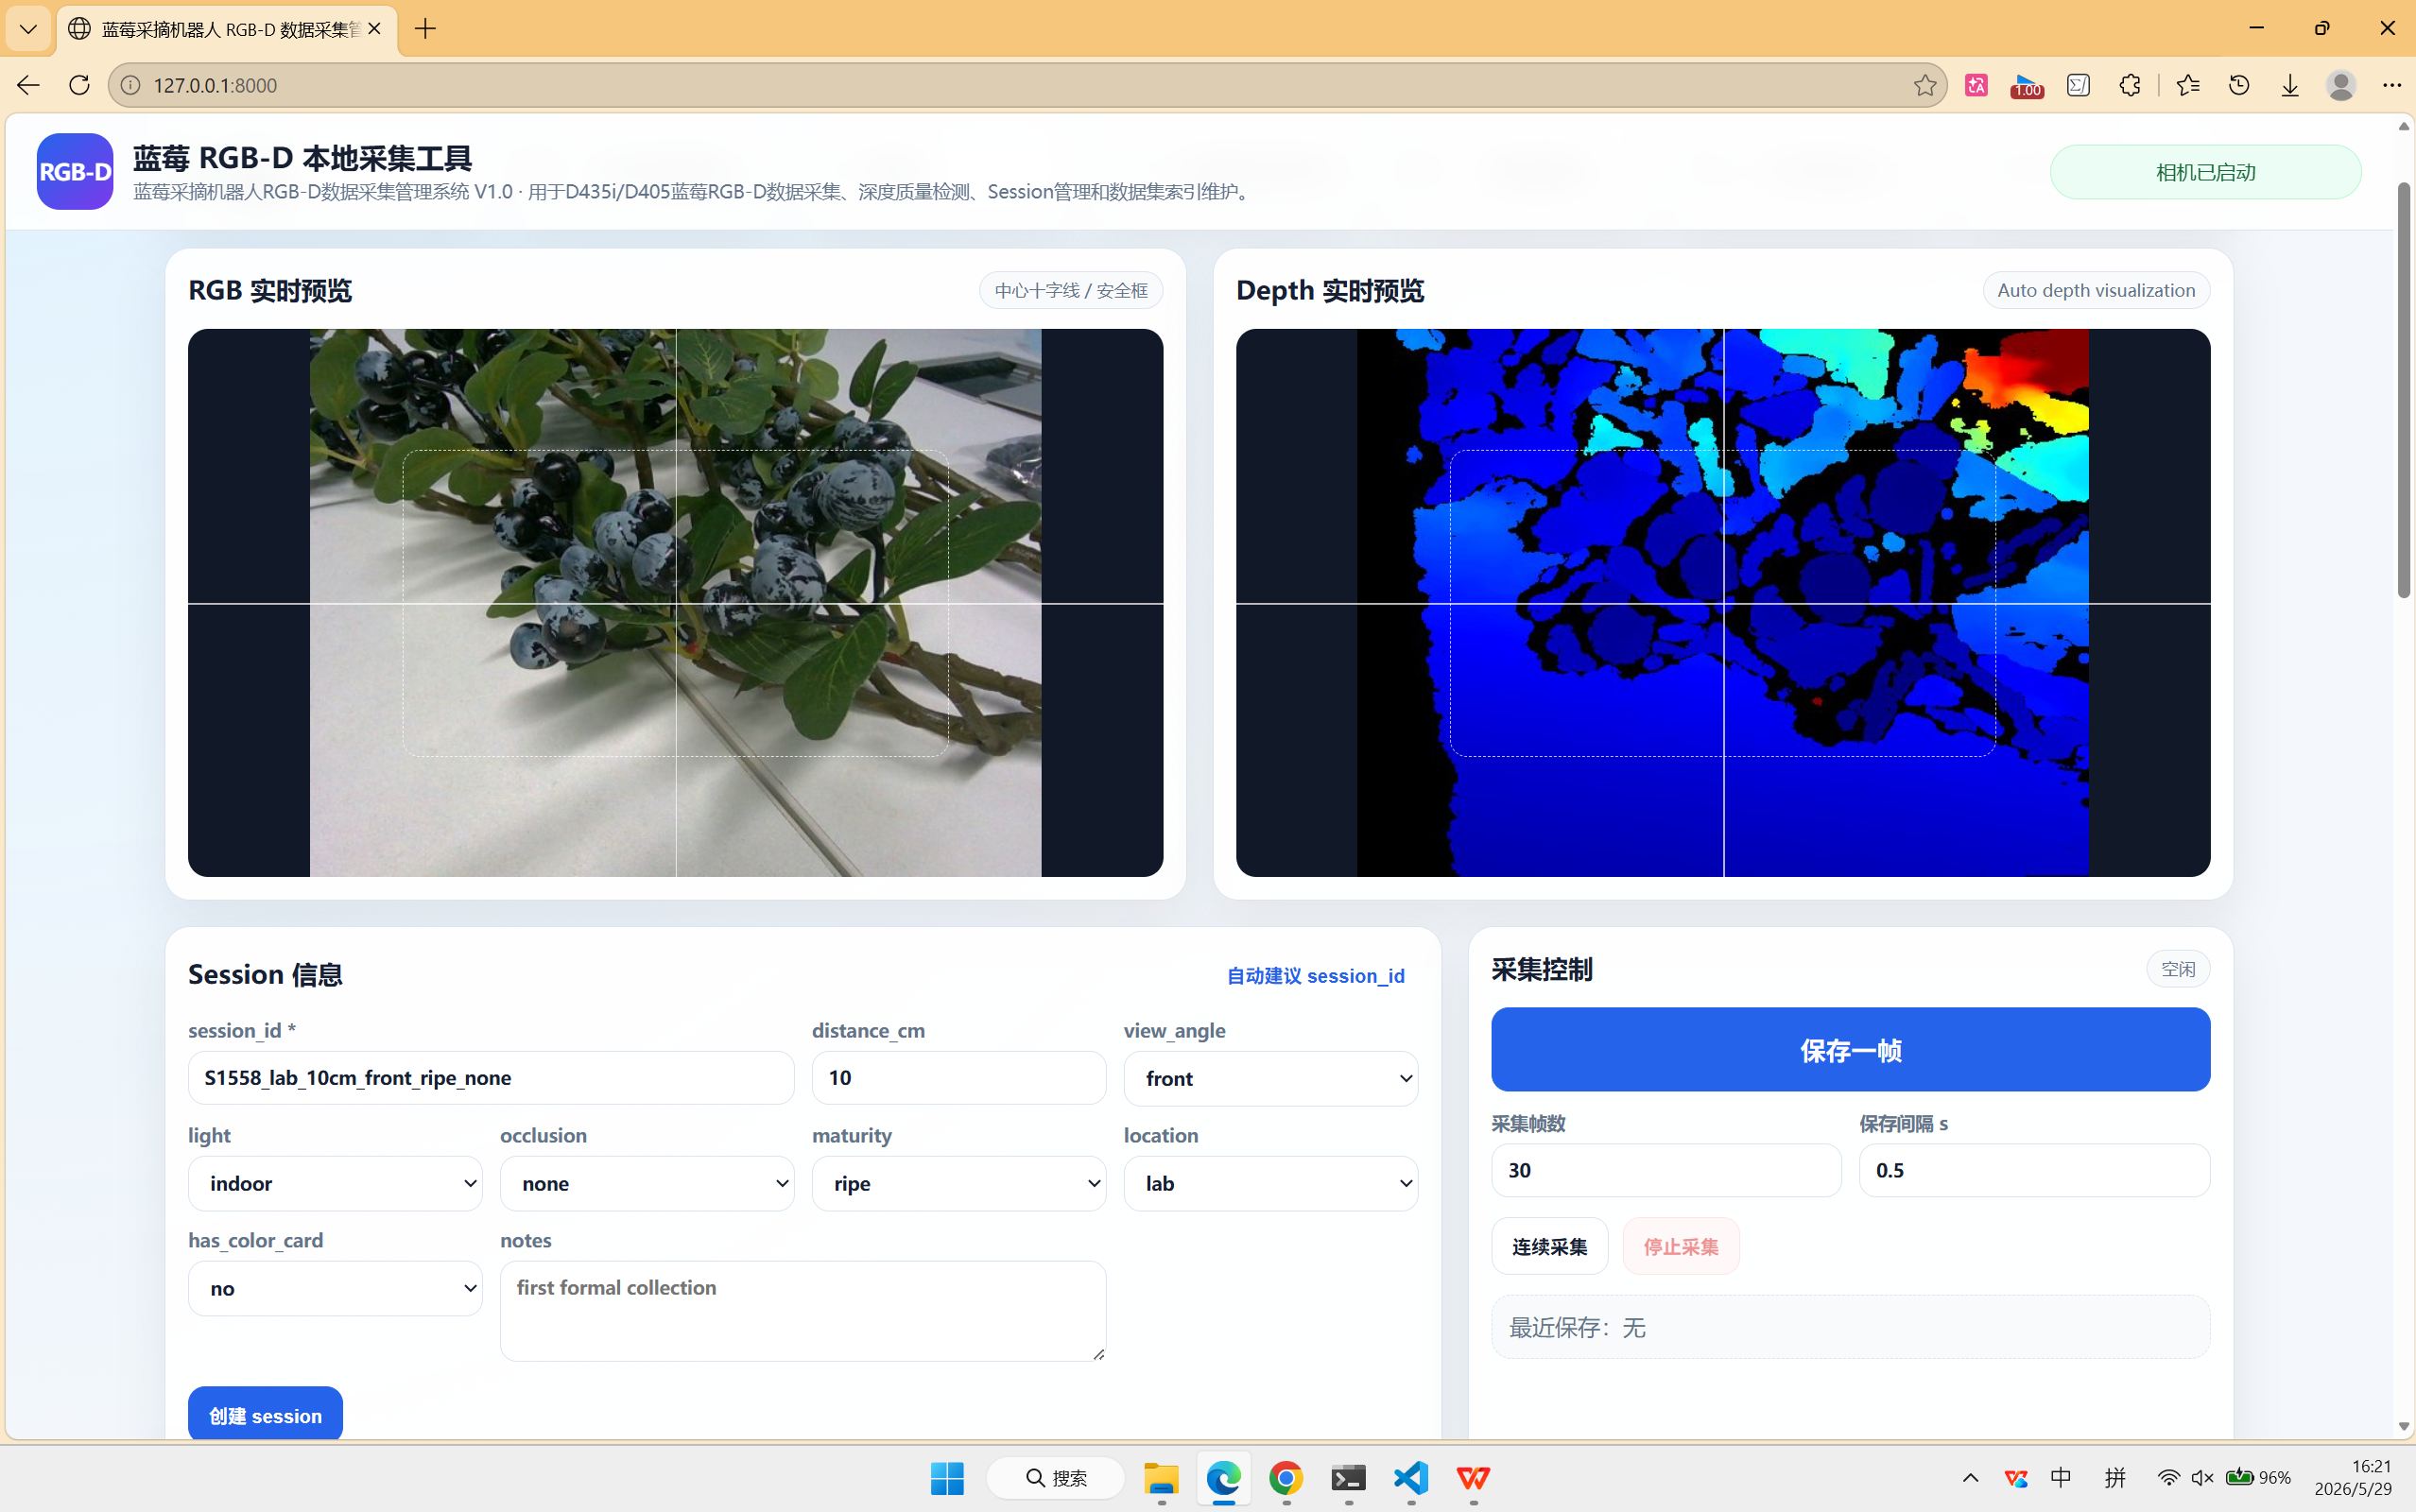
- Detects unripe, semi-ripe, and ripe blueberries with YOLOv8
- Provides image inference, confidence adjustment, history, dashboards, and CSV export
- Supports Intel RealSense D435i/D405 cameras, continuous capture, depth-quality metrics, session reports, and data-integrity audits
- Uses Python, FastAPI, SQLAlchemy, SQLite, OpenCV, Intel RealSense, and ECharts
Embodied Robotic Collaboration for Precision Assembly
Developed for the 2026 China College Students Mechanical Engineering Innovation and Creativity Competition, this system connects multimodal task understanding, VisionMaster visual communication, and an AUBO robotic-arm environment through a Python GUI console.
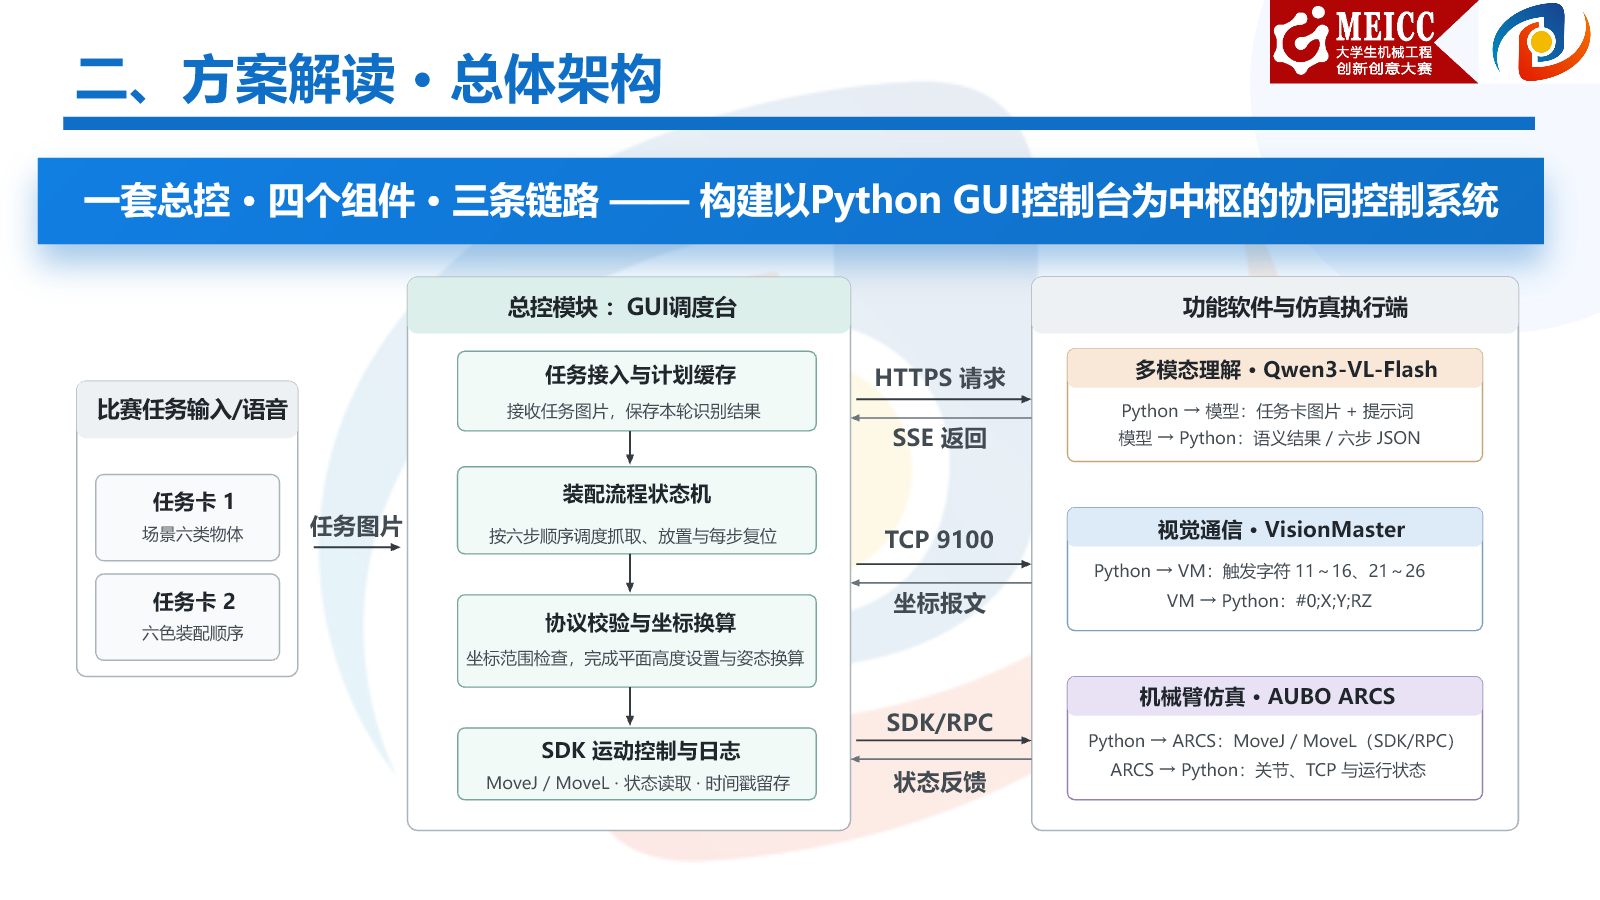
- Uses a multimodal model to parse task cards into structured assembly steps
- Applies deterministic validation rules before any robotic action is executed
- Connects VisionMaster through TCP and AUBO ARCS through its SDK/RPC interface
- Organizes coordinate conversion, motion control, recovery, and logging with a state machine
Our team, “具身不由己,” won First Prize in the Beijing–Tianjin–Hebei regional competition and advanced to the next stage.
Bayesian Inference and Dynamic Scoring in Voting Systems
This modeling project originated from the 2026 MCM/ICM Problem C and was subsequently developed into the journal paper Constrained Bayesian Reconstruction of Latent Public Preferences under Dynamic Elimination Rules: An Uncertainty-Aware Expert–Public Fusion Framework. It estimates hidden audience votes and compares alternative judging and elimination mechanisms.
The paper has been accepted by Axioms, with me as the third author. Volume, issue, page, and DOI information will be added after online publication.
- Uses Bayesian MCMC under hierarchical constraints to infer latent vote shares
- Compares ranking, percentage, and judges’ intervention mechanisms
- Proposes a Logistic Dynamic Weighted System whose audience and judges’ weights evolve during a season
- Archives the competition paper and reproducibility experiments
Read the competition paper (PDF)
Additional Engineering Projects
Three-Axis Gantry Puzzle Device
A vision-guided puzzle system developed for the 2026 Beijing College Student Electronic Design Competition. MaixCAM2 performs A4-board rectification, four-piece contour matching, pose estimation, and task planning, while an STM32F407 controls the three-axis gantry, electromagnetic gripper, and external rotation tray.
The team received Third Prize in the Beijing undergraduate division in August 2026.
Intelligent Rescue Vehicle
An autonomous rescue robot integrating OpenMV4 H7 Plus color vision with an STM32F407-controlled mecanum-wheel chassis. The system identifies colored rescue targets, estimates their horizontal offsets, and coordinates search, tracking, grasping, and transportation through encoder-based PID motion control.
The project received Second Prize in the university-level competition in April 2026.