OpenMV and STM32F407 Intelligent Rescue Vehicle
An autonomous rescue robot combining color vision, mecanum-wheel motion, and encoder-based PID control.
Overview
This project was developed for a university-level Engineering Practice and Innovation Competition in April 2026. The robot was required to operate autonomously in a simulated rescue field, identify colored rescue targets, and transport them to a designated safe zone.
Our system integrated vision, task logic, omnidirectional motion, and a front grasping mechanism. It received Second Prize at the university level.
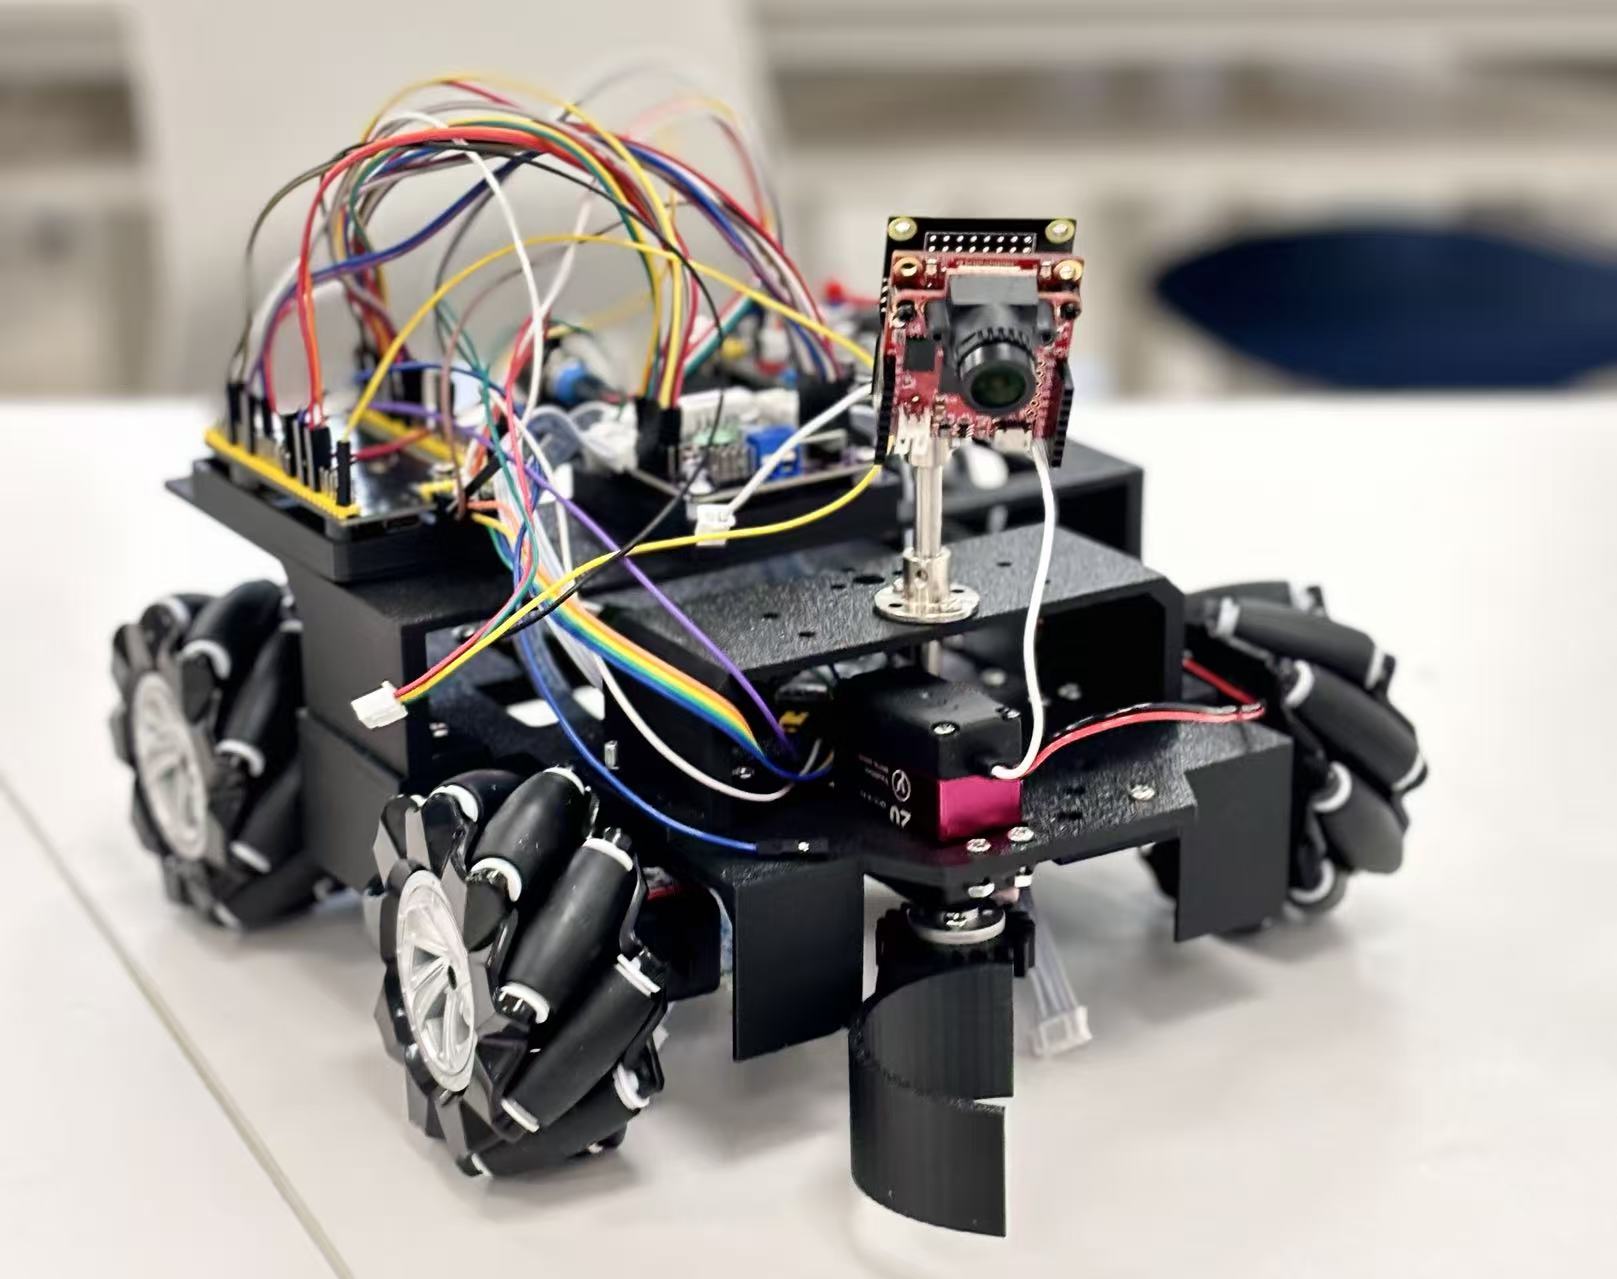
Final Architecture
An early K210 prototype was used to validate color thresholds, task states, and serial communication. After iterative testing, the final architecture used an OpenMV4 H7 Plus vision module and an STM32F407 as the main controller.
- Visual perception: OpenMV-based color thresholding, blob filtering, and target localization
- Task logic: search, tracking, approach, grasp/transport, and return-to-search modes organized around the competition rules
- Main controller: STM32F407 receives OpenMV results over UART and handles motion-mode transitions, velocity commands, and actuator control
- Chassis: a four-wheel mecanum platform driven through TB6612 channels, with quadrature-encoder feedback and PID wheel-speed control
Motion Control
The vision subsystem provides the target category, horizontal offset, and an approximate scale cue. The STM32F407 converts these observations into chassis commands (v_x), (v_y), and (\omega_z). Mecanum-wheel inverse kinematics then produces four wheel-speed targets.
At approximately 10 ms intervals, the controller reads each encoder, estimates the actual wheel speed, computes the PID output, and updates the TB6612 direction signals and PWM duty cycles. This closed loop helps reduce drift caused by motor differences and improves alignment during target approach and transportation.
Grasping Demonstration
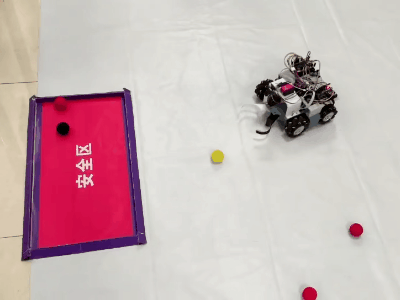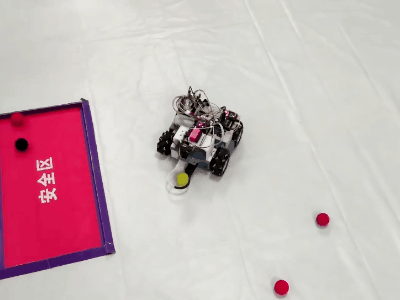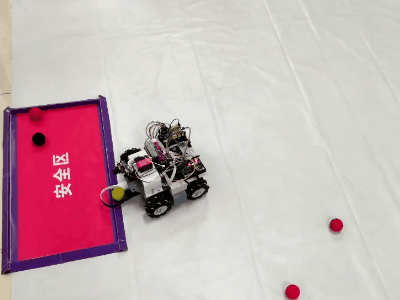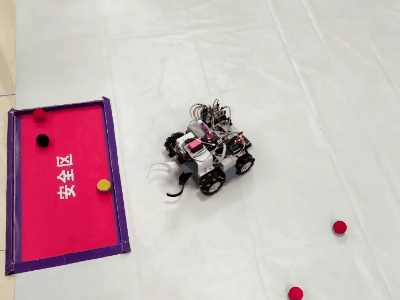
The animation below shows the robot approaching a colored target and using its front mechanism to grasp and transport it.
Engineering Work
- Decomposed the task into perception, decision, chassis-motion, and grasping subsystems
- Iterated from a K210 vision prototype to the final OpenMV4 H7 Plus solution
- Integrated STM32F407, TB6612 motor drivers, mecanum wheels, quadrature encoders, and PID control
- Debugged target-centering direction, wheel mapping, serial-frame parsing, and motion-control parameters
Technology
OpenMV4 H7 Plus · MicroPython · STM32F407 · C · STM32 HAL · Mecanum Wheels · TB6612 · Encoders · PID · UART